Open source software stack for the development of robotic applications.
Office Address
Plaza de la Encina 10-11, Núcleo 4, 2ª Pl.
28760 Tres cantos - Madrid (España)
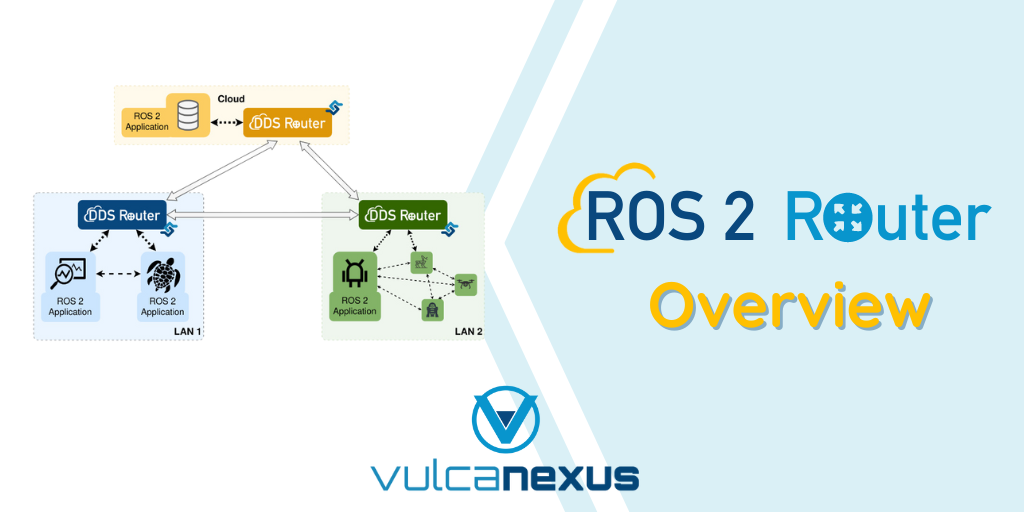
ROS 2 Router (a.k.a. DDS Router) is an end-user software application shipped with Vulcanexus Cloud that enables the connection of distributed ROS 2 networks that would otherwise be isolated. This solution offers an easy deployment due to a configurable modular system.
Vulcanexus releases a new Humble 2.4.0 version with many new components' features, improvements, and bug fixes.
Vulcanexus, the All-in-One ROS 2 tool set, has raised 10M in the new EU project “ARISE”, having the objective of empowering the European industry, especially the AI, data, and robotics ecosystem, with a robust, real-time enabled open-source middleware for industrial robotics applications.
This Vulcanexus SIMULATION use case is a step-by-step guide on how to map a Webots environment with the teleoperation of a ROSbot XL robot from Husarion.
Vulcanexus is thrilled to announce the release of the new Vulcanexus Iron Imagination version that supports ROS 2 Iron and brings many new features and tools such as the DDS Record and Replay and the DDS Spy.
Exciting news! Vulcanexus, the all-in-one toolset for ROS 2, is now in the Snap Store. Snapcraft, the Linux app store, provides a secure and effortless way to install and use Vulcanexus packages. Discover the potential of these open-source ROS2 tools today!
Vulcanexus releases a new Humble 2.2.0 version that comes with many new features, improvements, and bugfixes of all components. Vulcanexus, the all-in-one ROS 2 tool, is always updated to the latest versions, avoiding manual updates and extra configurations. Keep reading to find out more about all the upgraded components:
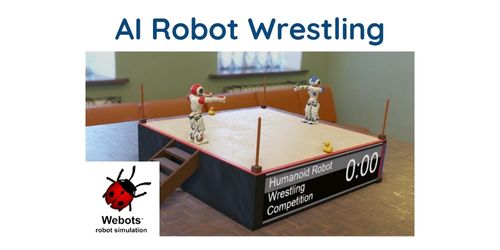
Have you ever heard about AI Robot Wrestling?
Vulcanexus' official partner Cyberbotics offers a never seen Humanoid Robot Wrestling Competition using their top simulation tool Webots.
eProsima recently undertook a thorough analysis of the main open-source DDS implementations and their performance in terms of latency and throughput.
Open source software stack for the development of robotic applications.
Plaza de la Encina 10-11, Núcleo 4, 2ª Pl.
28760 Tres cantos - Madrid (España)